Insect-Scale Biped Robots Based on Asymmetrical Friction Effect Induced by Magnetic Torque

Multimodal and controllable locomotion in complex terrain is of great importance for practical applications of insect-scale robots. Robust locomotion plays a particularly critical role. In this study, a locomotion mechanism for magnetic robots based on asymmetrical friction effect induced by magnetic torque is revealed and defined. The defined mechanism overcomes the design constraints imposed by both robot and substrate structures, enabling the realization of multimodal locomotion on complex terrains. Drawing inspiration from human walking and running locomotion, a biped robot based on the mechanism is proposed, which not only exhibits rapid locomotion across substrates with varying friction coefficients but also achieves precise locomotion along patterned trajectories through programmed controlling. Furthermore, apart from its exceptional locomotive capabilities, the biped robot demonstrates remarkable robustness in terms of load-carrying and weight-bearing performance. The presented locomotion and mechanism herein introduce a novel concept for designing magnetic robots while offering extensive possibilities for practical applications in insect-scale robotics.

相关文章

  • Multicarbide Evolution and High-Temperature Failure Mechanisms of Non-spherical WC-Reinforced Ni-Based Coatings
    [Bowen Dai, Li Zhang, Shengli Li, Houlin Ning, Zhiwen Xie]
  • Oral nano-delivery of a gut microbial metabolite enhances T cell stemness for cancer immunotherapy
    [Kai Han, Young Seok Cho, Mariko Takahashi, Xingwu Zhou, Hannah E. Dobson, Kim Hutchings, Yuesong Wu, Youngseo Na, Fang Xie, Julia Crowther, Jinmei Wu, Jin Xu, Chuan Lee, Himani Jasewicz, Yujin Kim, Minal Nenwani, Olamide Animasahun, Fulei Wuchu, Anthony Andren, Harrison Wong, Emma Camp, Ziye Wan, Qi Wu, Li Zhang, Cheng Xu, Katherine Dong, Yao Xu, Anna Schwendeman, Grace Y. Chen, Yuying Xie, Costas A. Lyssiotis, Martin Clasby, Deepak Nagrath, Yu Leo Lei, James J. Moon]
  • Aneuploidy selects for the acquisition of driver genes in breast cancer
    [Khalid N. Al-Zahrani, Ellen R. Langille, Jocelyn Nurtanto, Andreea Obersterescu, Katie Teng, Christopher Lowden, Julien Dessapt, Cynthia H. Chiu, Lauren V. Caldwell, David P. Cook, Miguel A. Pérez-Castro, Jacob M. Berman, Ricky Tsai, Alexander T. Bahcheli, Geraldine Mbamalu, Shifei Wu, Masahiro Narimatsu, Adele G. Lopes, Iosifina Fotiadou, Kin Chan, Linkang Zhang, K. W. Annie Bang, Michael J. Parsons, Larissa Mourao, E. Idil Temel, Liddy McCulla, Palavalasa Sravya, Li Zhang, Peter Sajjakulnukit, Costas A. Lyssiotis, Alexander D. Borowsky, Colinda L. G. J. Scheele, Daniel R. Wahl, Hartland W. Jackson, Katherine S. Stewart, Elaine Fuchs, Sean E. Egan, Miguel Angel Pujana, Jüri Reimand, Jeffrey L. Wrana, Daniel Schramek]
  • qq

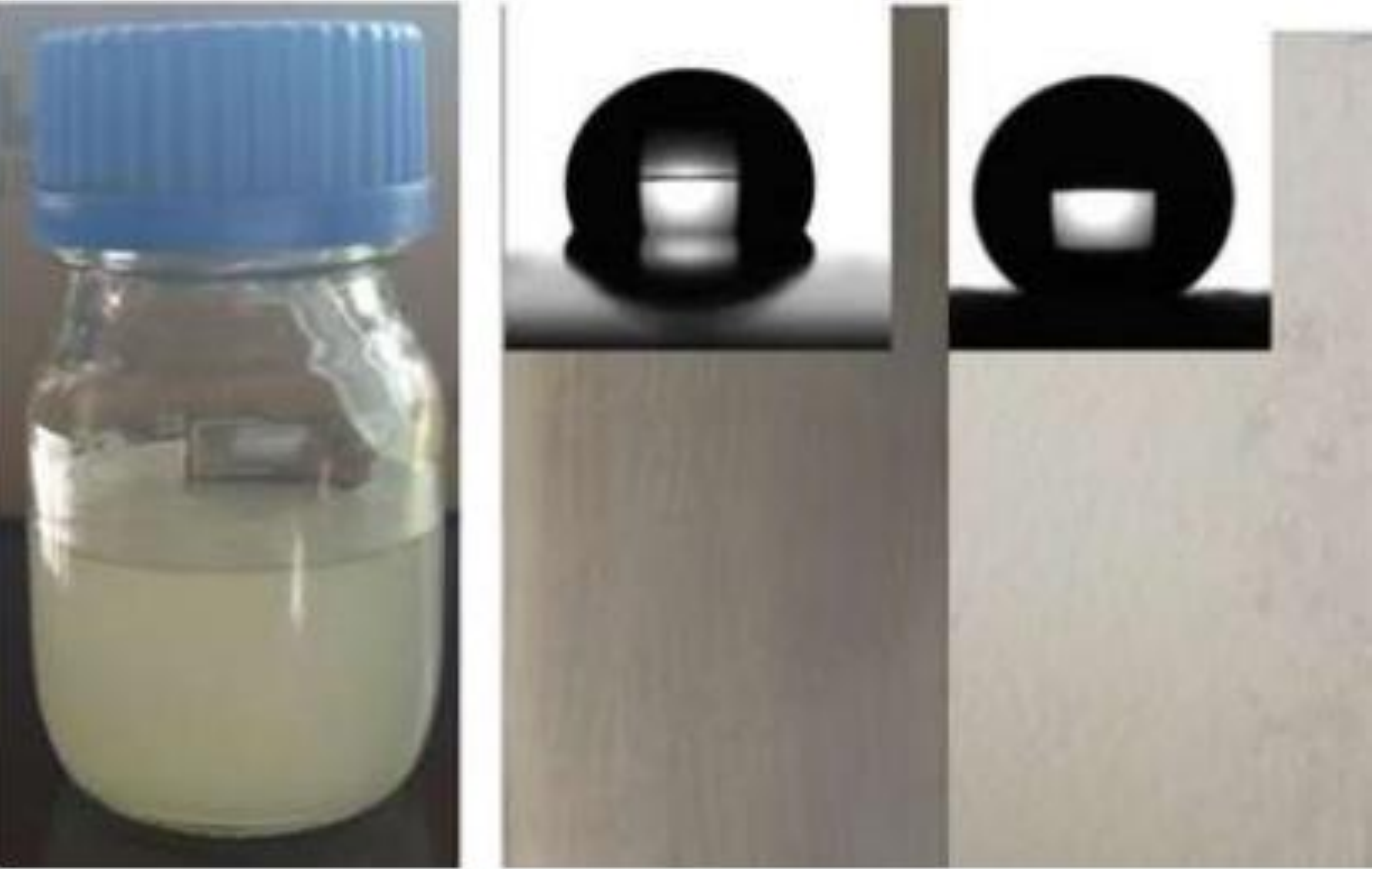
    成果名称:低表面能涂层

    合作方式:技术开发

    联 系 人:周老师

    联系电话:13321314106

    ex

    成果名称:低表面能涂层

    合作方式:技术开发

    联 系 人:周老师

    联系电话:13321314106

    yx

    成果名称:低表面能涂层

    合作方式:技术开发

    联 系 人:周老师

    联系电话:13321314106

    ph

    成果名称:低表面能涂层

    合作方式:技术开发

    联 系 人:周老师

    联系电话:13321314106

    广告图片

    润滑集